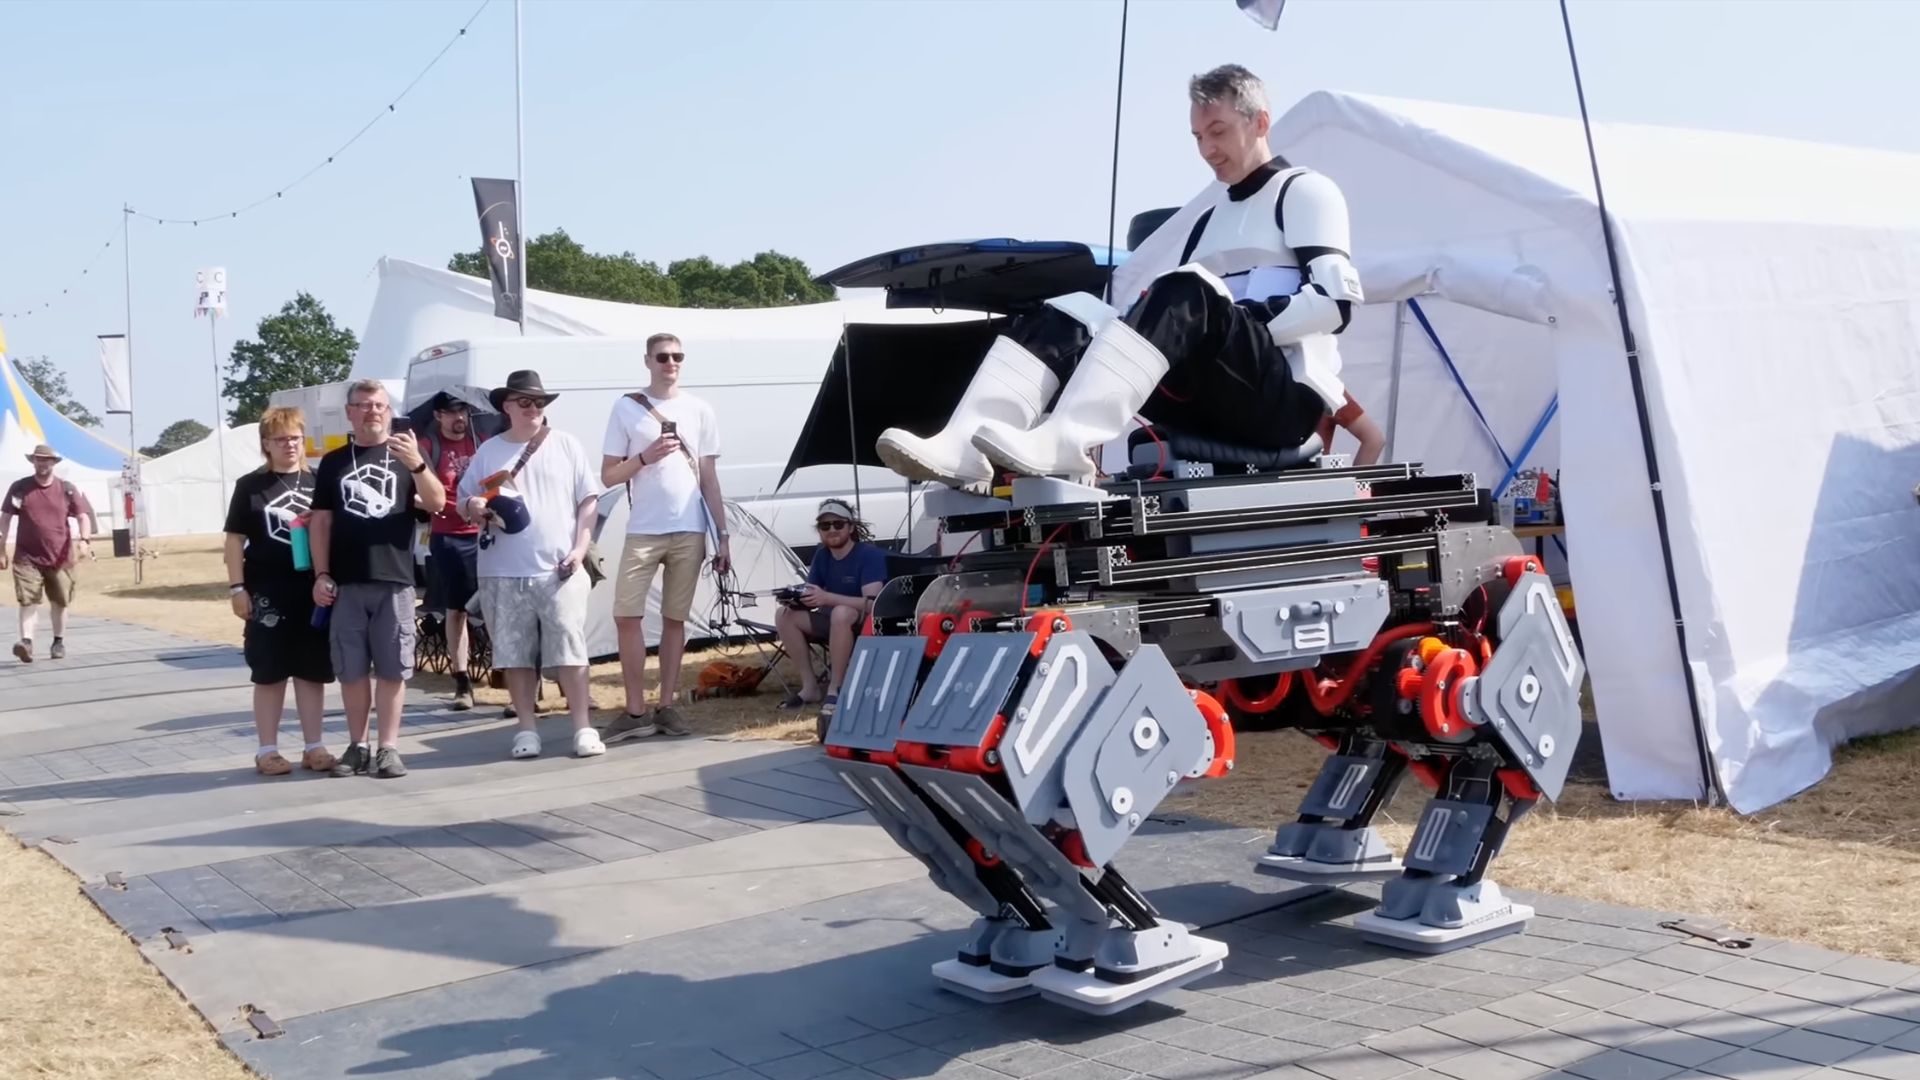
James Bruton's Mid-Walker quadruped robot is an impressive feat of engineering, but its journey to becoming a reliable carrier of humans across various terrains has been a challenging one. The robot's initial design, with its diagonal legs and sliding seat, showed promise on flat ground. However, the real test of its mettle came when it encountered uneven terrain, highlighting a critical weakness in its design. The robot's feet, initially made of hard materials, struggled to adapt to the unpredictability of the ground, leading to instability and potential tipping. This issue prompted Bruton to explore innovative solutions, drawing inspiration from everyday objects like bean bags and 3D-printed dice.
One of the key challenges was finding the right material and structure for the feet. Bruton's experiments with bean bags and 3D-printed dice showed promise, but they weren't without their limitations. The filling needed to move and conform to the ground while maintaining stability under heavy loads. The dice couldn't prevent shifting when the machine leaned, and the plastic coverings eventually failed under stress. This led to a reevaluation of the foot design, with a focus on durability and adaptability.
Bruton's next design will incorporate passive two-way pivot ankles that can self-level before bar clamps lock them in place. This approach aims to improve the locking effect and make the feet rigid after they conform to the ground. Load cells or an inertial sensor could detect firm contact and trigger the clamps without adding another motor to the walking system. This simplification is a welcome development, as it addresses the complexity introduced by the sliding seat mechanism.
The Mid-Walker's journey from a compact walking machine to a potential human carrier across various terrains is a testament to Bruton's ingenuity and perseverance. While the robot still has its limitations, the continuous improvements and innovative solutions are bringing it closer to its goal. As Bruton continues to refine the design, the Mid-Walker may one day become a reliable and versatile companion for humans, capable of navigating a wide range of environments with ease.